 Get Listed
Sign In
CAN Bus Explained Part 3
29/07/2026
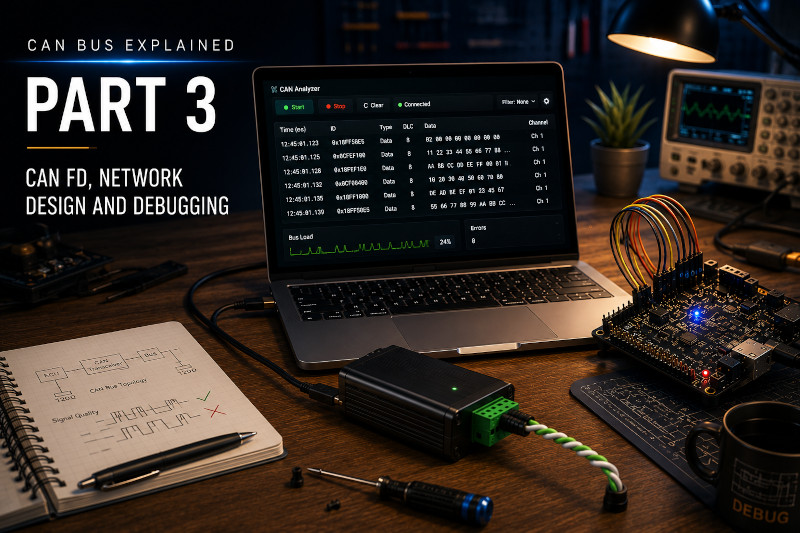
The final part of Kanda’s CAN Bus series looks at the newer developments and practical considerations involved in real CAN networks.
Building on the earlier explanations of differential signalling, frame structure and arbitration, the article explores CAN FD, network design and the hardware and software tools used to analyse and debug CAN systems. The emphasis moves from protocol theory towards applying CAN reliably in working embedded and industrial projects.
Together, the three-part series provides a grounding in why CAN remains widely used in vehicles, automation and control systems. Its combination of deterministic communication, robustness and mature development tools continues to make it a practical choice for engineers designing dependable networked electronics.
Building on the earlier explanations of differential signalling, frame structure and arbitration, the article explores CAN FD, network design and the hardware and software tools used to analyse and debug CAN systems. The emphasis moves from protocol theory towards applying CAN reliably in working embedded and industrial projects.
Together, the three-part series provides a grounding in why CAN remains widely used in vehicles, automation and control systems. Its combination of deterministic communication, robustness and mature development tools continues to make it a practical choice for engineers designing dependable networked electronics.
For more information on CAN Bus Explained Part 3 talk to Kanda
Welcome back to FindTheNeedle.
Not registered? Get listed — most visitors don't have an account yet.
List your company on FindTheNeedle.